Fast and Accurate Gamma-Ray/Hadronic Particle Shower Classification Using Machine Learning

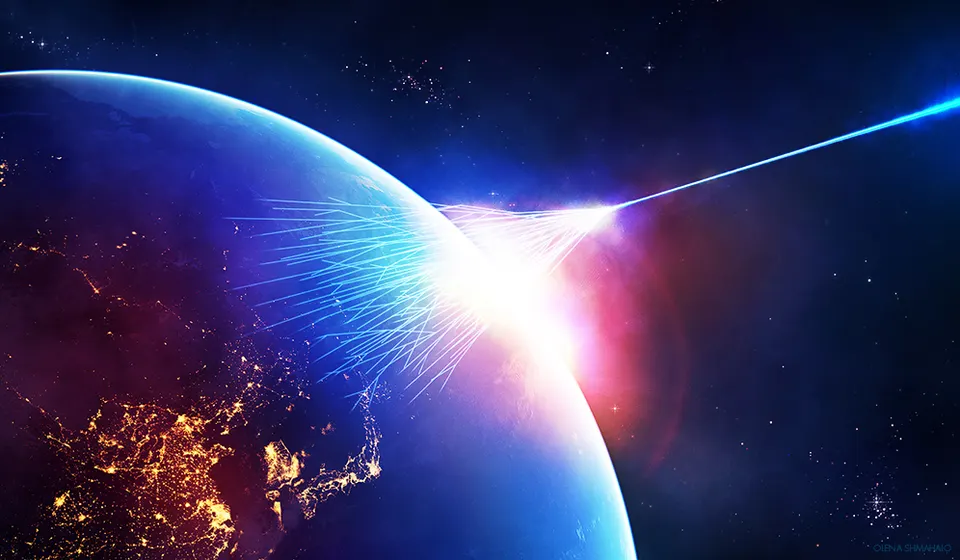
This research applies dimensionality reduction techniques, such as Pearson Correlation and Principal Component Analysis, to machine learning models like Random Forests and Support Vector Classifiers to simplify the prediction of atmospheric gamma-ray particle showers, achieving a modest accuracy increase while reducing the number of features used.
Correct and efficient prediction of atmospheric gamma-ray particle showers is important because the study of these initiating particles can lead us to discoveries about the parts of the universe from which they originated. Previous research has been done with datasets similar to the one we chose, all of which go deep into the optimization of machine learning methods to solve this classification problem. However, we have yet to see researchers try to simplify their model in order to maintain high model performance while minimizing the number of features used. Because of this, we used dimensionality reduction methods like Pearson Correlation and Principal Component Analysis on sklearn classification models like Random Forests and Support Vector Classifiers to try and solve this issue. It was found that with a Pearson Correlation Coefficient cut-off of 0.01, model accuracy was increased from 87.51% to 87.83% while reducing the number of features used by two, meaning our goal was accomplished. In addition, a stacking ensemble yielded an accuracy of 88.04% with fast predicting speed.
Explore More!
Related Projects


© 2022 Inspirit AI. All Rights Reserved.