Back To Projects

A Late Fusion Approach with Multimodal Image-Text Data

Shreyes B.

This project explores late fusion methods in multimodal machine learning to improve emotion detection by combining image and text predictions, and evaluates their effectiveness compared to other fusion approaches using the MVSA-Single dataset.


As the number of users on social media platforms continues to rise, an increasing number of people are expressing their emotions and opinions. Before the popularity of multimodal machine learning, previous works included identifying texts and images separately to determine sentiment. However, these studies often overlooked features that other modalities could capture that are crucial to emotion. Recent advances in multimodal machine learning are now making essential and precise judgments in image recognition [1]. In this project, we explore a specific type of fusion called late fusion, demonstrating its ability to combine different modalities. In particular, we highlight two late fusion methods that combine the predictions of the image and text models. Additionally, we investigate a contrastive learning approach, which will help improve the visual embeddings, making them more discriminative in feature space. We compare the strengths and limitations of late fusion against other fusion approaches. Our findings are based on experiments conducted with the publicly available MVSA-Single dataset.

Explore More!
Shreyes B.
Varsha Sandadi

Related Projects

Predictive Analysis of Aircraft Engine Lifespan: Leveraging Neural Networks on NASA's C-MAPSS Dataset

This research paper explores the application of neural networks for predictive maintenance of aircraft engines, focusing on the estimation of their Remaining Useful Life (RUL).
Sambhav A.
Mentored by
Adapting Martian Rover Technology for Terrestrial Disaster Response and Extreme Terrains

This research examines how technological advances in Martian rovers, from autonomous navigation to adaptive suspension systems, can inform solutions for disaster response and operation in inaccessible regions on Earth. A 3D-printed rover prototype and global disaster data were used to evaluate the potential of ground-based rovers to complement aerial systems in challenging environments.
Humayl F.
Mentored by Rami Abi-Akl
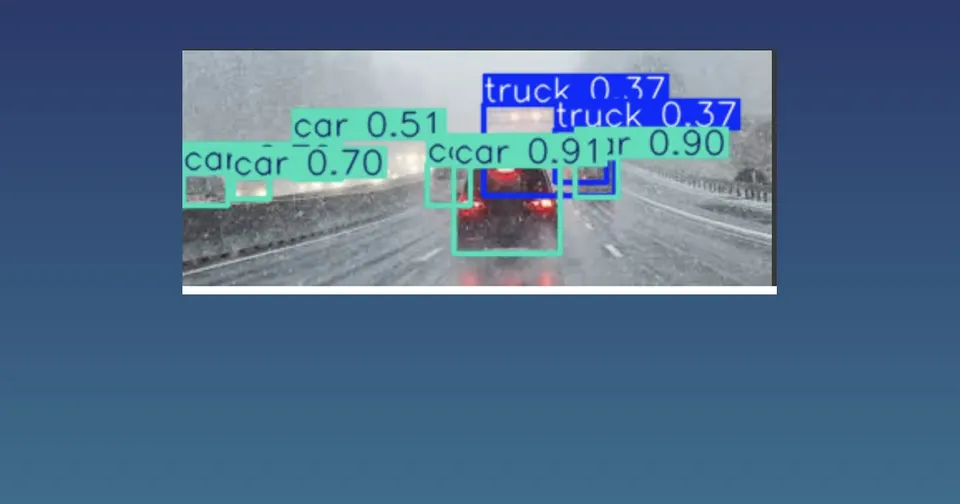
Enhancement of Autonomous Vehicles During Extreme Weather

This research investigates improving object detection for autonomous vehicles in extreme weather by fine-tuning the YOLOv8n neural network. Starting with a pretrained model that struggled to recognize vehicles in rain, fog, and snow, we used the DAWN dataset from Kaggle to retrain it, raising detection accuracy from about 22 percent to over 90 percent in poor-visibility conditions while increasing confidence levels by roughly 40 percent, though at the cost of slightly reduced performance and traffic-light detection in normal conditions.
Pandian A.
Mentored by Udgam Goyal