Back To Projects

A Methodology for Learning Airplane Descent Patterns

Michael T.

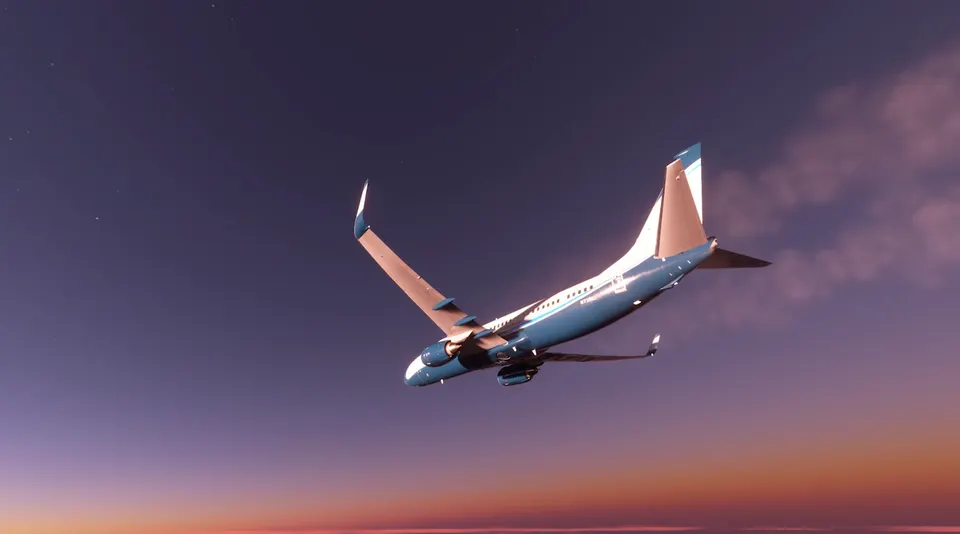
In this study, we trained a plane to land without human assistance.


In this study, we trained a plane to land without human assistance. We did this using reinforcement learning, a type of machine learning where the agent (the AI “pilot” in this case) runs iterations of the task and adjusts its methodology depending on this interaction with its environment. This agent-environment interaction is called the Markov Decision Process, and is the heart of reinforcement learning. This is an important problem to solve as reinforcement learning applications like these can be used to improve the safety and quality of life for people who are regularly traveling. Additionally, the fact that reinforcement learning can be used to solve problems like these implies further applications in complex fields like flight and other modes of transportation. To figure out how to train a plane to land, we used OpenAI Gym to build a simulated environment where we tested different landing maneuvers. Initially, we experimented with optimizing the angle of attack for variables like time taken to land and descent rate, but ultimately found it most effective to optimize for having the lowest velocity when the plane reaches the ground. Further research could potentially experiment with how different variables such as speed, acceleration, and angles of the left and right ailerons affect the plane’s landing.

Explore More!
Michael T.
Sean Konz
Computer Science MS from Stanford, Software Engineer

Related Projects

Human-Robot Task Handoff: A Probabilistic Modeling Approach Explored through Cooperative Drawing

This paper investigates the task of handoff detection, crucial for the success of robot-assisted surgery, focusing on the creation of a synthetic dataset that can be used for training and benchmarking models for this task.
Lucas C.
Mentored by Ross Greer
Predicting Unplanned Electric Vehicle Breakdowns using Machine Learning on Sensor and Diagnostic Data

This study explores the use of artificial intelligence (AI) for fault prediction in electric vehicles (EVs) to reduce unexpected breakdowns and improve reliability. Using sensor, driving, and diagnostic data from 2020–2024, the research found that tree-based models, particularly Decision Tree and Random Forest, achieved over 90% predictive accuracy, demonstrating AI’s potential to enable proactive maintenance and enhance user confidence in EV technology.
Richa K.
Mentored by Rami Abi-Akl
Path Planning for Autonomous Cinematic Drones

This study explores autonomous drone navigation for aerial cinematography, focusing on algorithms that enable drones to smoothly reach specified locations while maintaining high-definition camera quality. Using a simulation environment, the study tested multiple path planning algorithms and found that A* consistently outperformed others in both accuracy and efficiency, making it the most suitable for enhancing autonomous drone cinematography.
Brayden T.
Mentored by Rima Rebei